Abstract
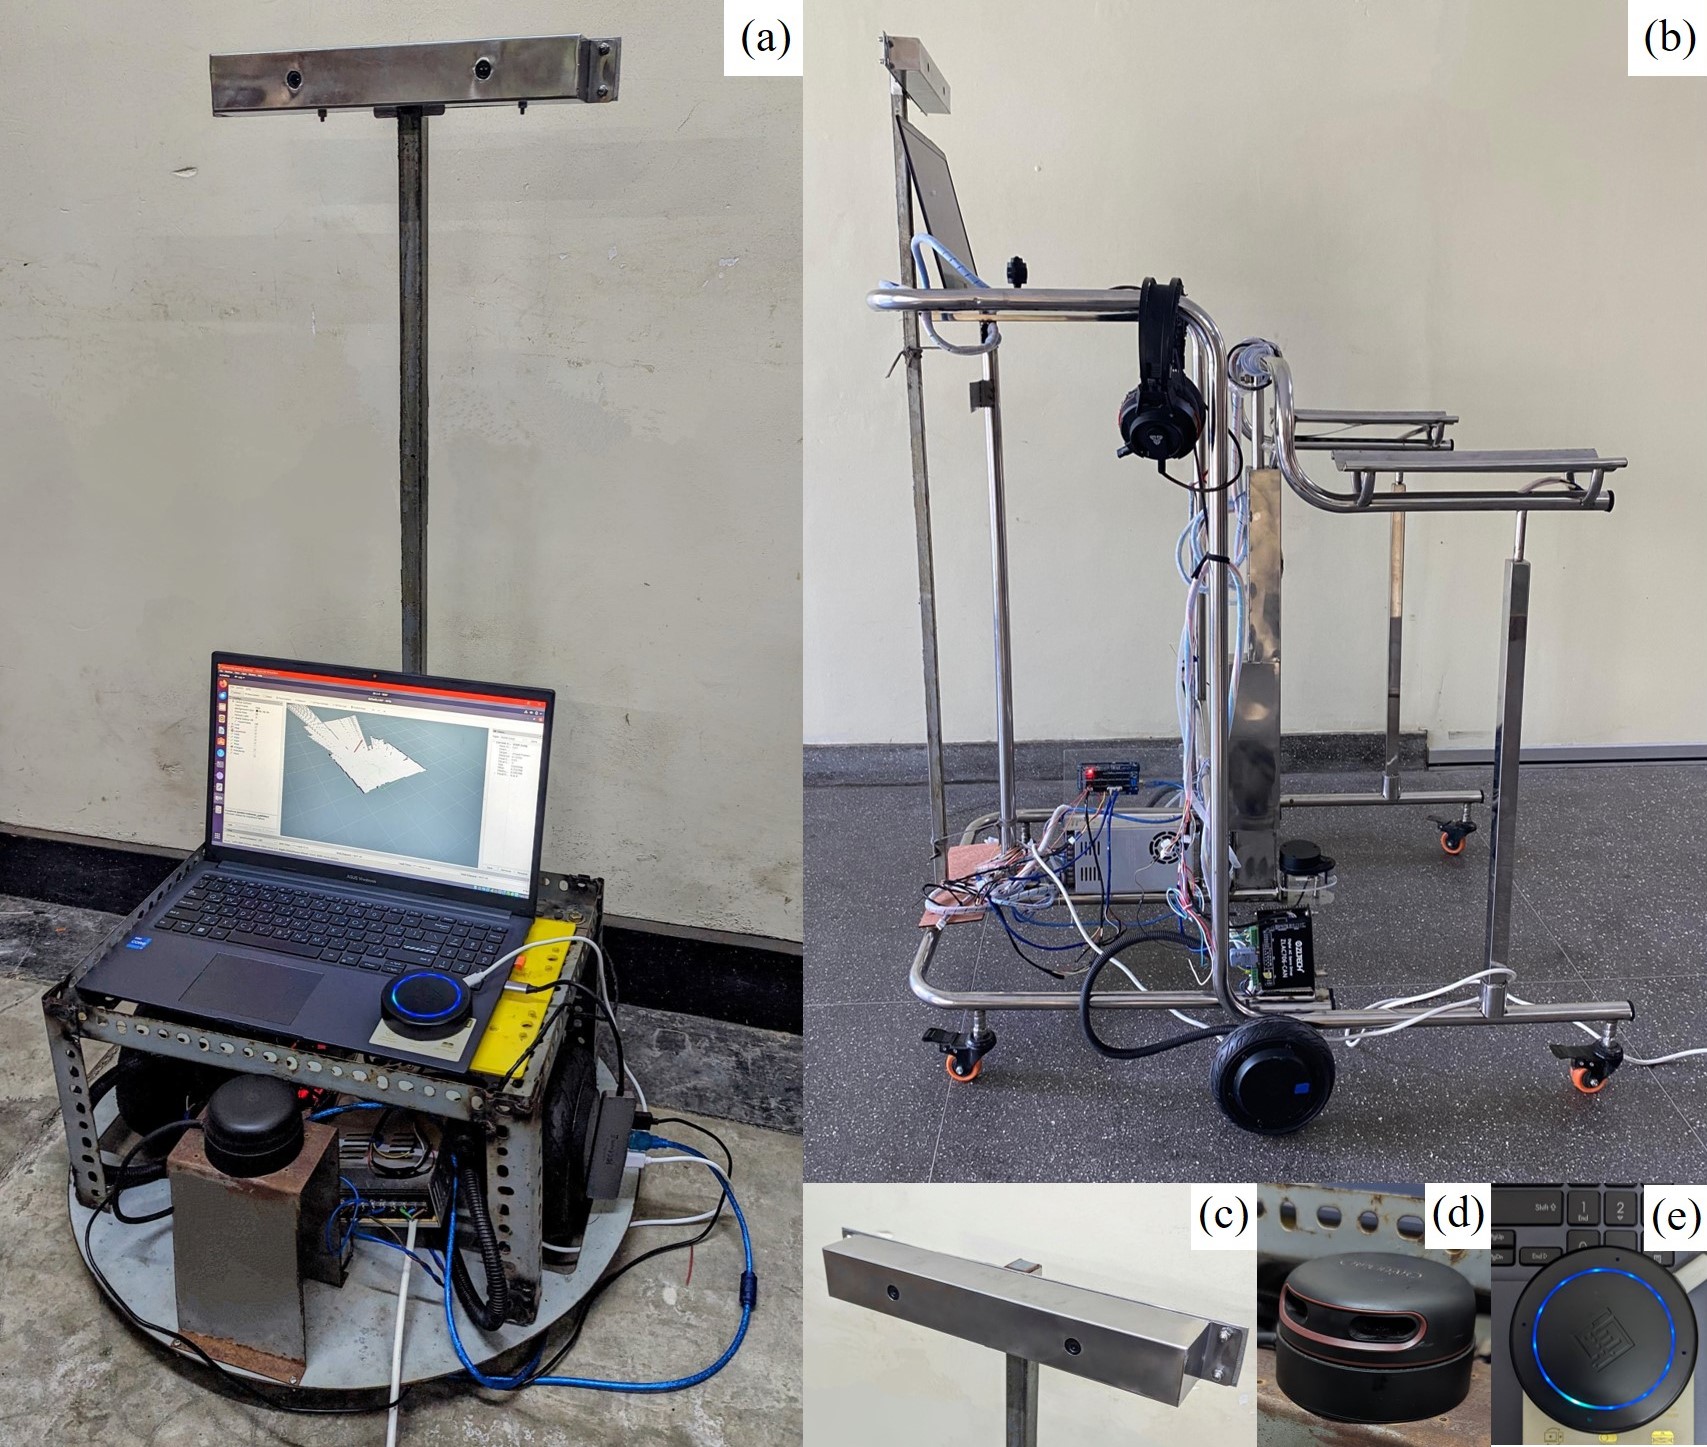
This work presents a Patient Assistive Mobile Robot equipped with robust summoning and navigation capabilities. Our system addresses the crucial need for assistive robots to respond reliably to patients’ requests, even in scenarios involving out-of-sight calls. To achieve this, we integrate three core technologies: 1) LiDAR-based SLAM for accurate localization and mapping, providing a foundational spatial understanding; 2) Sound source localization to determine the direction of calls from outside the robot’s line-of-sight; and 3) Stereo vision-based gesture recognition and depth estimation, enabling intuitive interaction when the patient is visible. This multifaceted approach ensures that our Patient Assistive Mobile Robot can navigate complex environments and respond effectively to a broader range of summoning methods, enhancing its utility and dependability in healthcare settings.
Functionalities
- LiDAR-based SLAM for Localization and Mapping
- Sound Source Localization for out of line-of-sight navigation
- Gesture Recognition and Depth estimation by Stereo Vision for line-of-sight navigation